 Agent
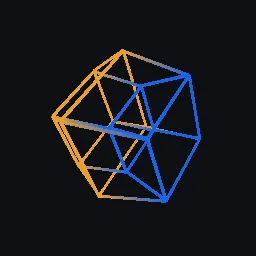
What this component contains
ATTRIBUTION.mdLICENSEREADME.mdcomponent.jsonexample.gltffourd.pypreview.pngrotation_exp_log.pytest_package.pyverification/native.json
How it works
- Entry points
- generator, is_skew, generator_angles, expm, rotation_angles, logm, classify, geodesic and 7 more
- Outputs
- example.gltf
- Coordinates
- x, y, z, w; frames projected in perspective to Godot/glTF +Y up
Recorded checks
godot 4.7.2.stable.official.ed1daf0bf
cli_rebuilds_examplegltf_structure_examplecli_example_runscli_example_gltf_structuregodot_loads_examplegodot_loads_cli_24cell_isoclinicpreview_render
Limits to consider
The animation stores keyframes as morph targets, so vertices move along chords between keyframes: the largest deviation from the true rotation is 1 - cos(step/2) of the radius (0.0086 for the example with 48 frames and rate 2). Tubes are unlit three-sided prisms whose positions are morphed without normal targets. The logarithm is ill-conditioned for nearly isoclinic rotations, where the invariant planes are not unique, and picks one plane pair for rotations by pi.